Mohammed Naveedh
Mechanical Engineering undergraduate at NIT Andhra Pradesh with coursework at IIT Madras. Building closed-loop vehicle control stacks, drive-by-wire calibration, and edge vision platforms.
National Winner • ISRO Problem Statement
Nationwide Founder Teams • INR 1,00,000 Award
Selected from 7,500+ National Innovations
Overall Finalist among 250+ National Teams
Autonomous EV Control & Drive-by-Wire
ROS2 Control Stack & CAN Telemetry
Engineered the distributed vehicle control stack on an autonomous electric vehicle at IIT Madras. Integrated RTK-GNSS positioning, CAN vehicle telemetry, and a custom PyQt5 operator cockpit.
KnightAngle: Edge AI ADAS Calibration
Software-Defined ADAS Calibration
Developing an edge camera calibration platform for vehicle ADAS sensors. Selected in the Top 100 teams from 7,500+ submissions in Tata Technologies InnoVent-27. Replaces physical calibration bays with edge vision algorithms.
Work & Research.
Hands-on engineering across autonomous testbeds, founder initiatives, and electric motorsport.
Research Intern, Autonomous Systems Lab
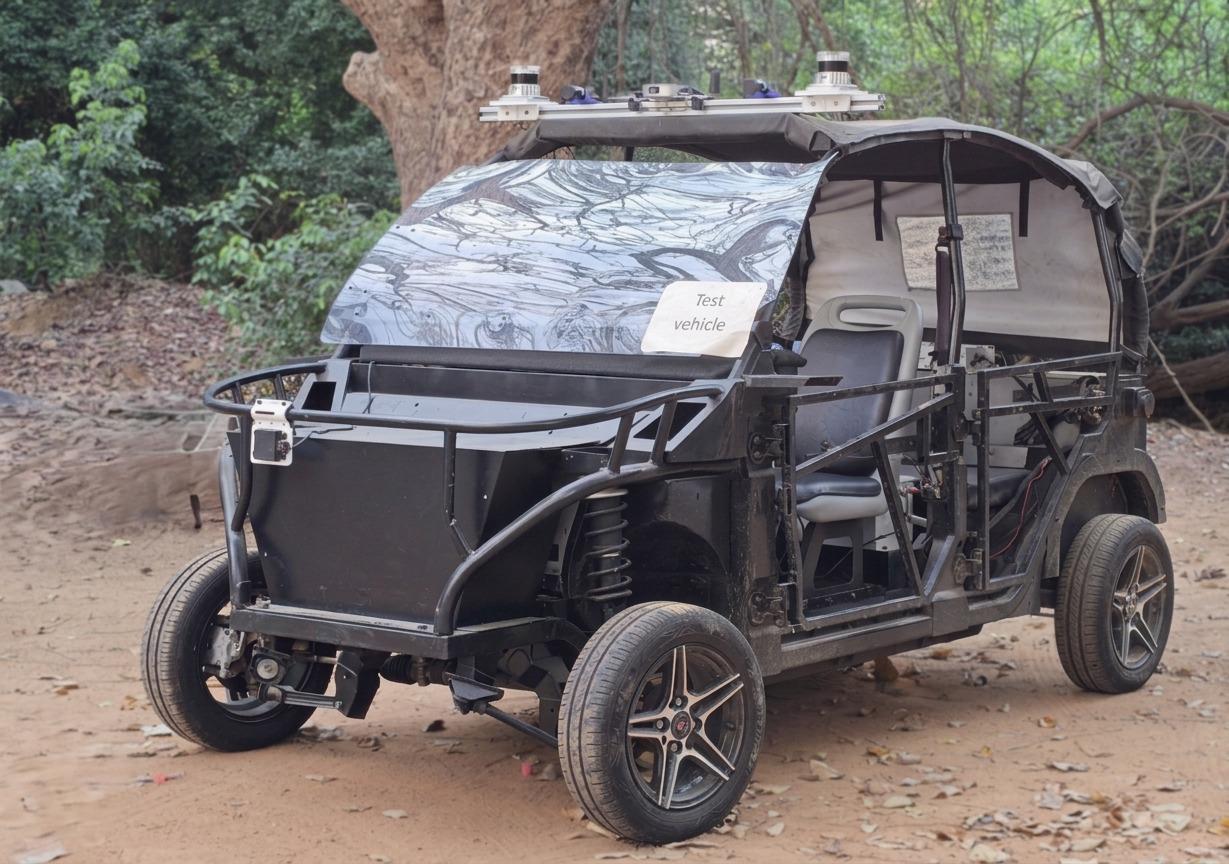
Developed and validated a controller-ready steering subsystem for an autonomous EV, implementing automatic steering calibration, steering ratio estimation, and closed-loop position control on a physical testbed.
Engineered software-based steering calibration with CAN feedback, eliminating additional steering sensors while enabling repeatable center referencing and fault handling.
Evaluated Bezier trajectory generation with Pure Pursuit and Stanley path tracking in ROS2/Gazebo simulation for real vehicle deployment.
Team Lead — Future Founders Program
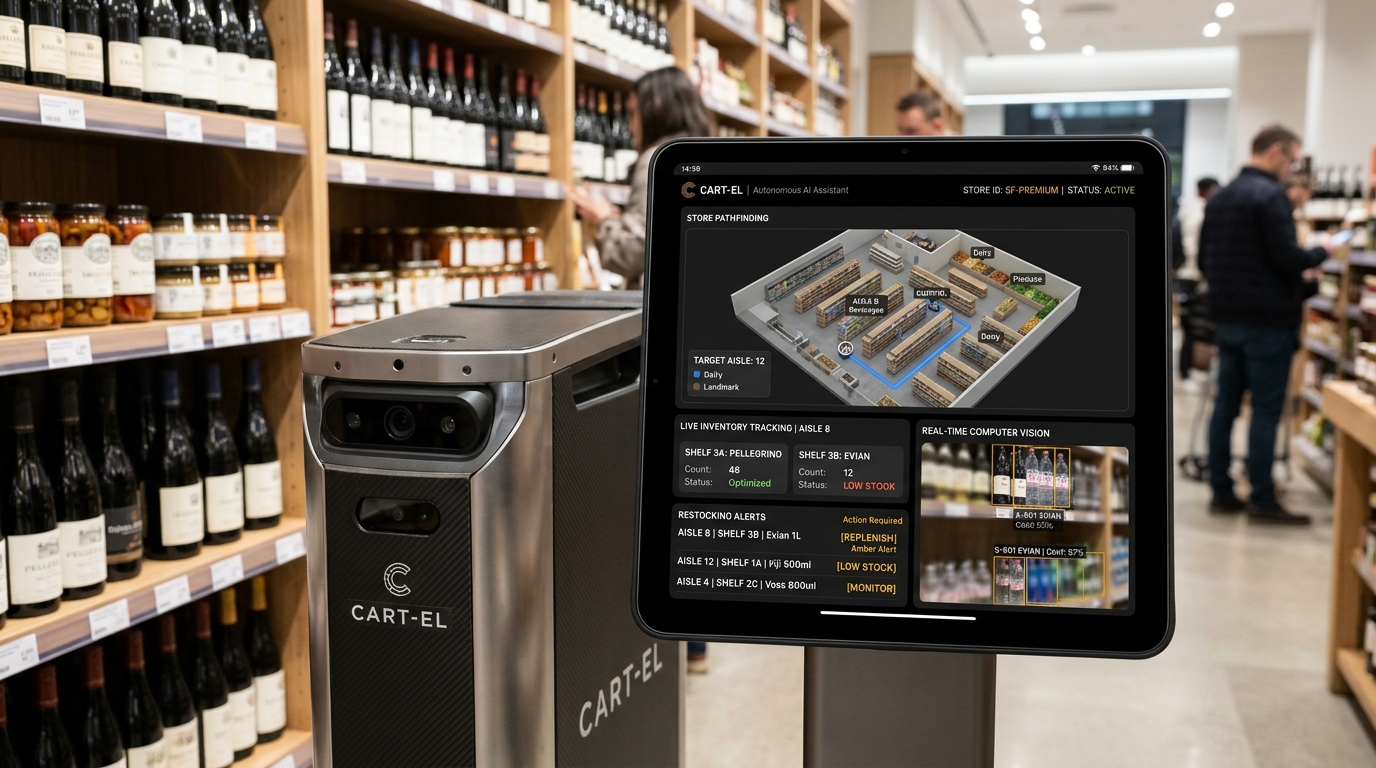
Led a 3-member team during an 8-week nationwide program with 756 teams to build CART-EL, an AI-powered retail business assistant.
Drove merchant discovery, problem validation, and live deployment at a supermarket managing 15,000+ SKUs; awarded 1st Place nationwide and INR 1,00,000.
EV Go-Kart Team — Formula Kart Design Challenge (Season 9)
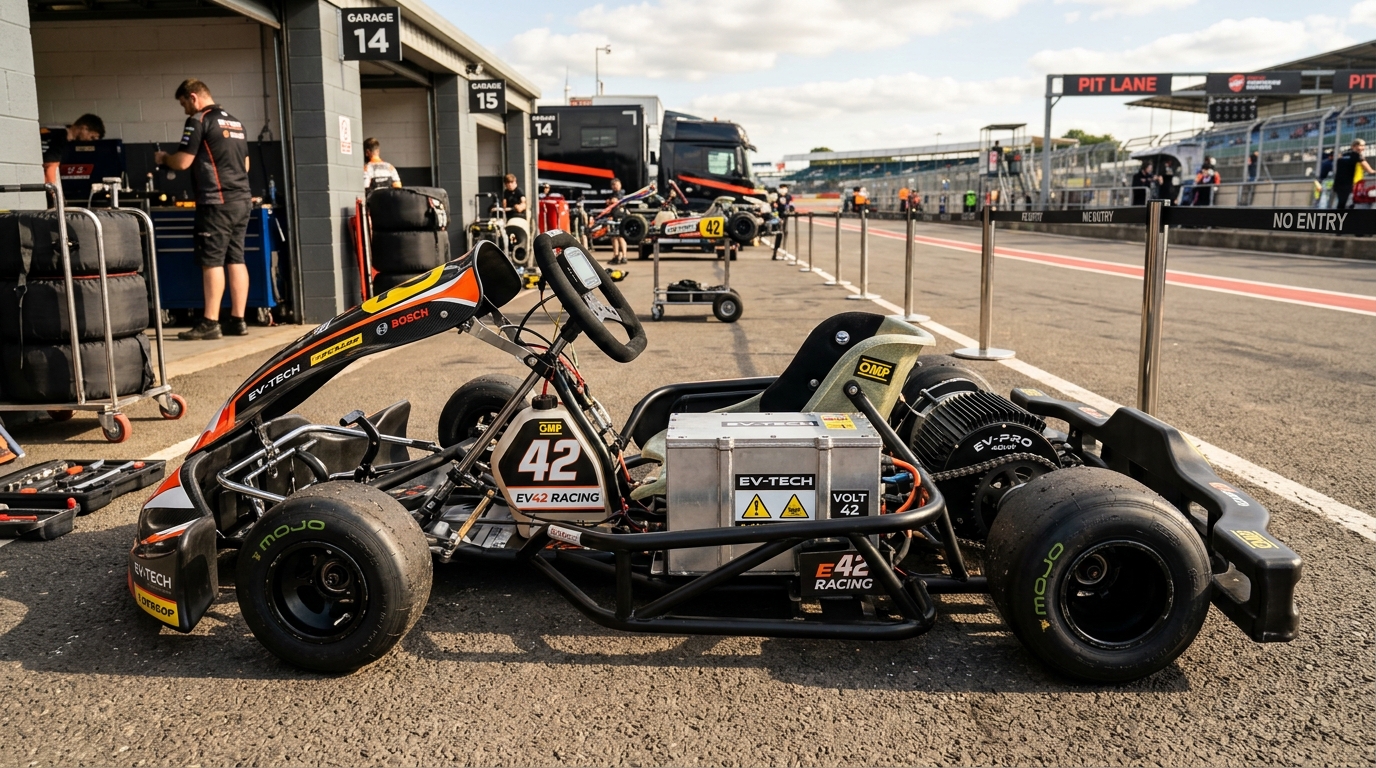
Owned technical and business documentation for a 14-member EV team, covering powertrain architecture, chassis FEA rationale, and cost-performance analysis.
Contributed to AIR 4 in Design Presentation; team achieved AIR 7 Overall (EV Category), AIR 5 in Endurance, and AIR 6 in Acceleration at Kari Motor Speedway.
Projects & Hackathons.
Autonomous navigation, space robotics, and software prototypes validated in competition and lab settings.
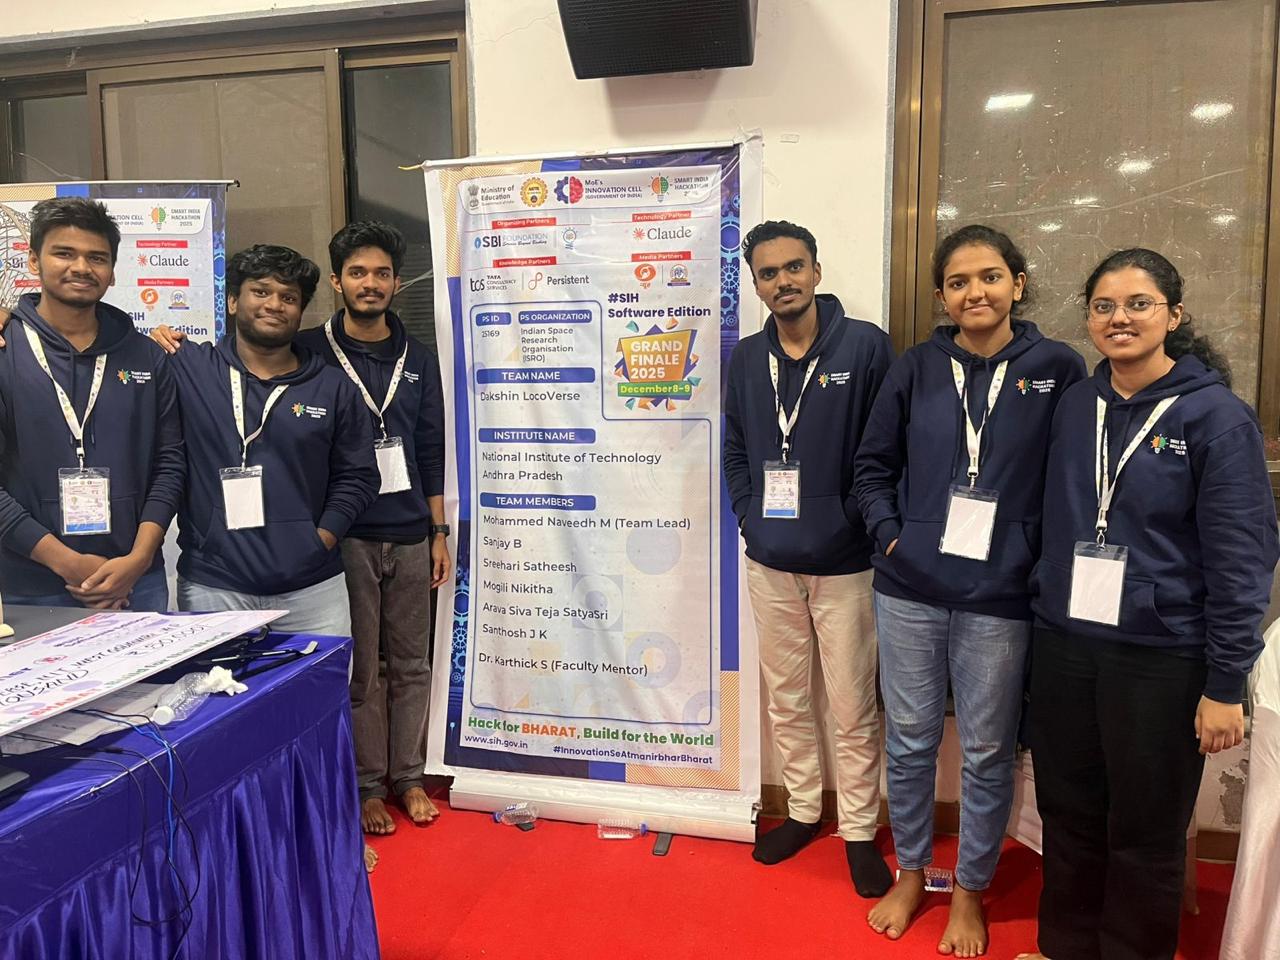
Autonomous Lunar Habitat Navigation
Team Lead for Dakshin LocoVerse, winning the Smart India Hackathon Grand Finale for ISRO's autonomous lunar navigation challenge. Developed full ROS2 Nav2 mobile robotics navigation on custom lunar surface models.
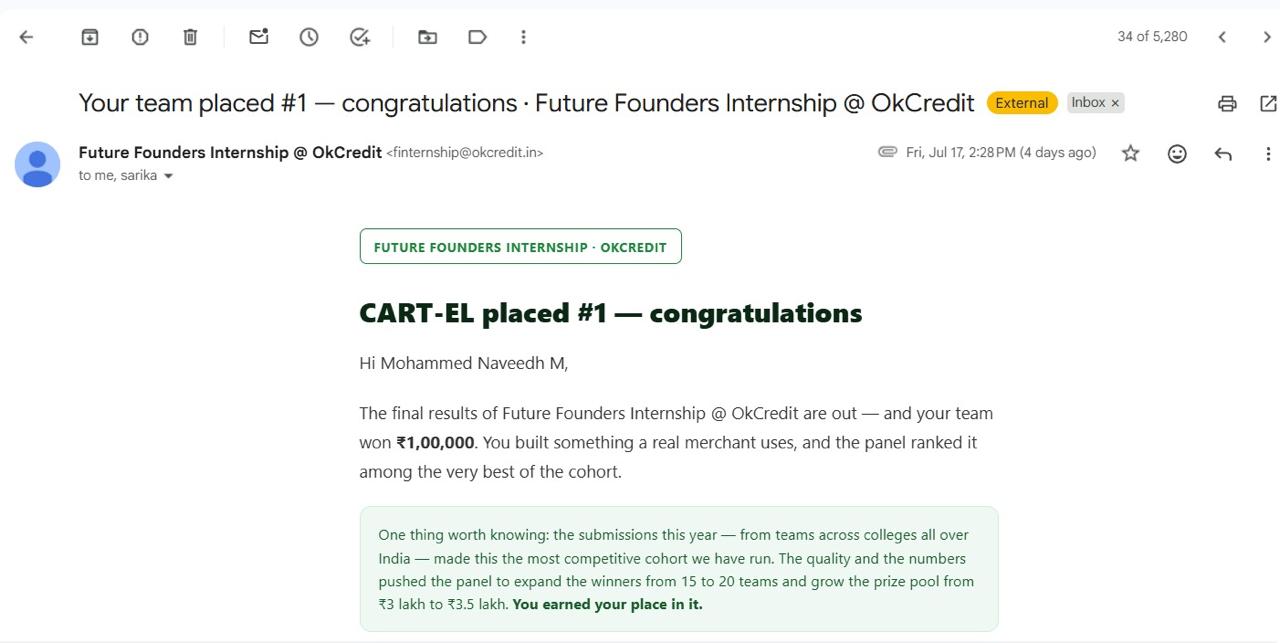
CART-EL: AI Retail Assistant
Led a 3-member team across 8 weeks to build and validate an AI-powered retail assistant, deployed live in a supermarket managing 15,000+ SKUs.
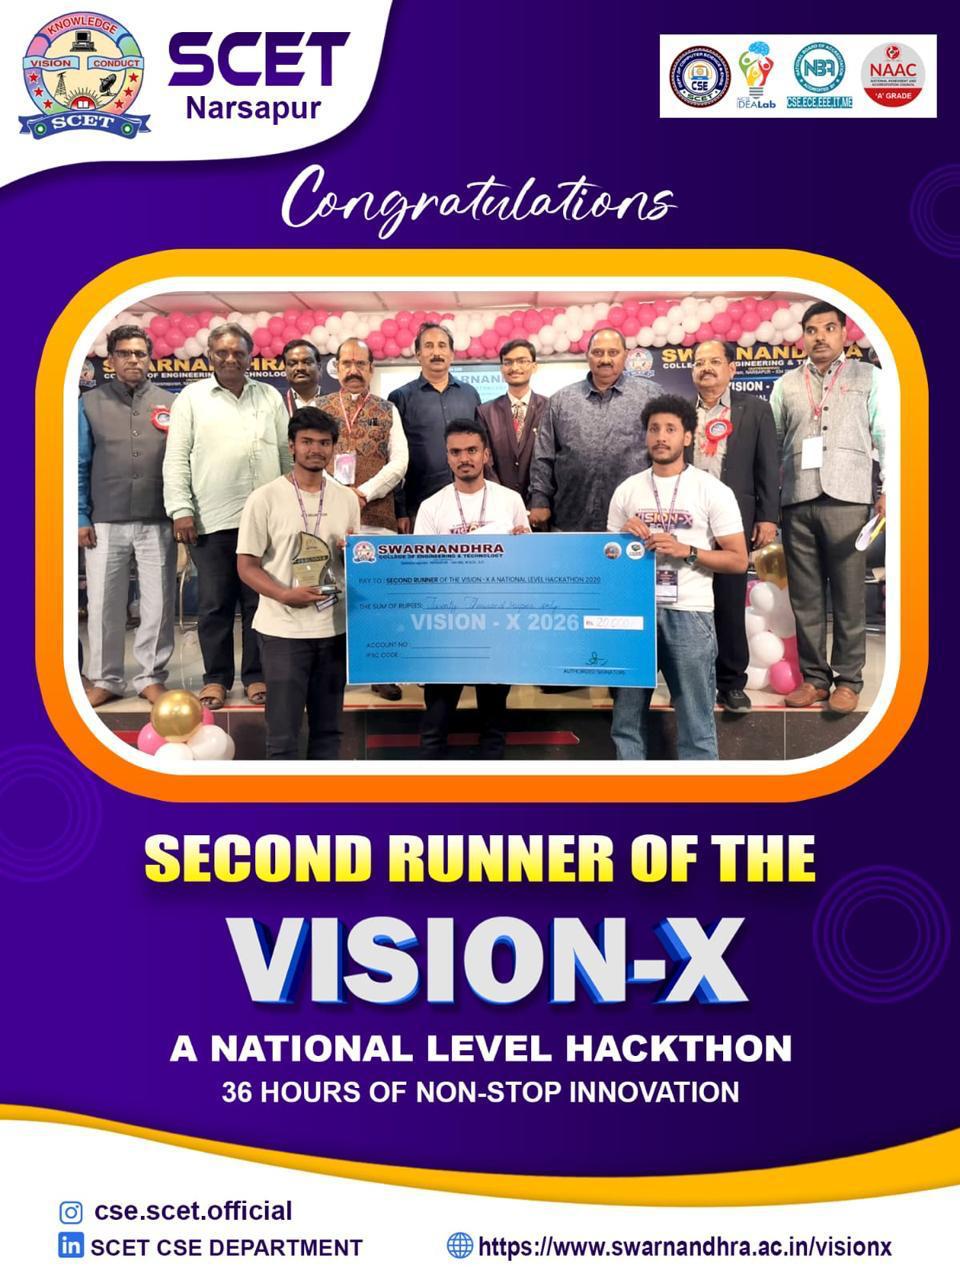
LunarISRU: Resource Utilisation Simulation
Team Captain leading simulation of in-situ lunar resource utilisation in Gazebo with mission-planning and task-execution logic for unstructured terrain.
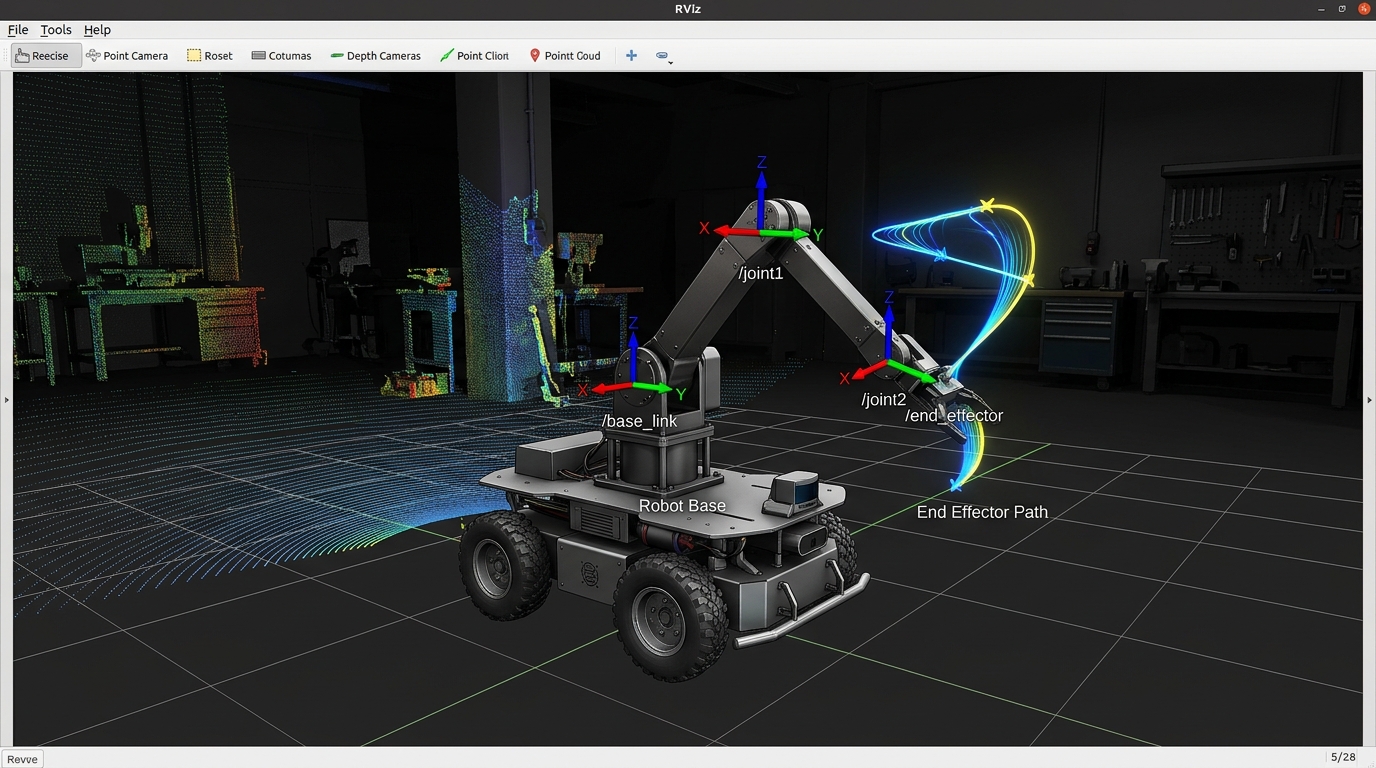
Robotic Arm on Mobile Base
Designed and simulated a 2-DOF robotic manipulator on a differential-drive mobile base using ROS2 and Gazebo, developing synchronized arm-base control pipelines.
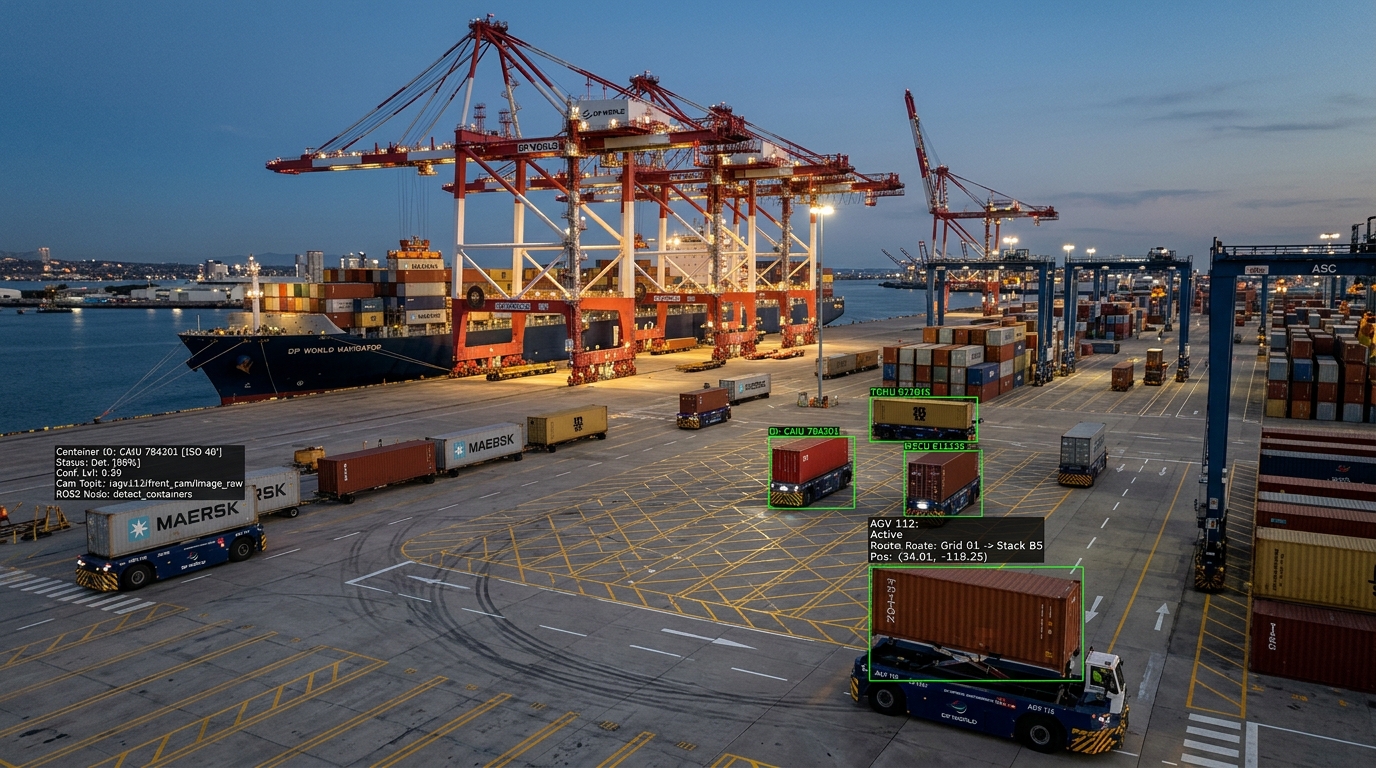
Automated Cargo Intelligence System
Led team developing a Gazebo harbour simulation with automated guided vehicles (AGVs) and conveyor networks, using ROS2 camera topics and RViz for real-time inspection.
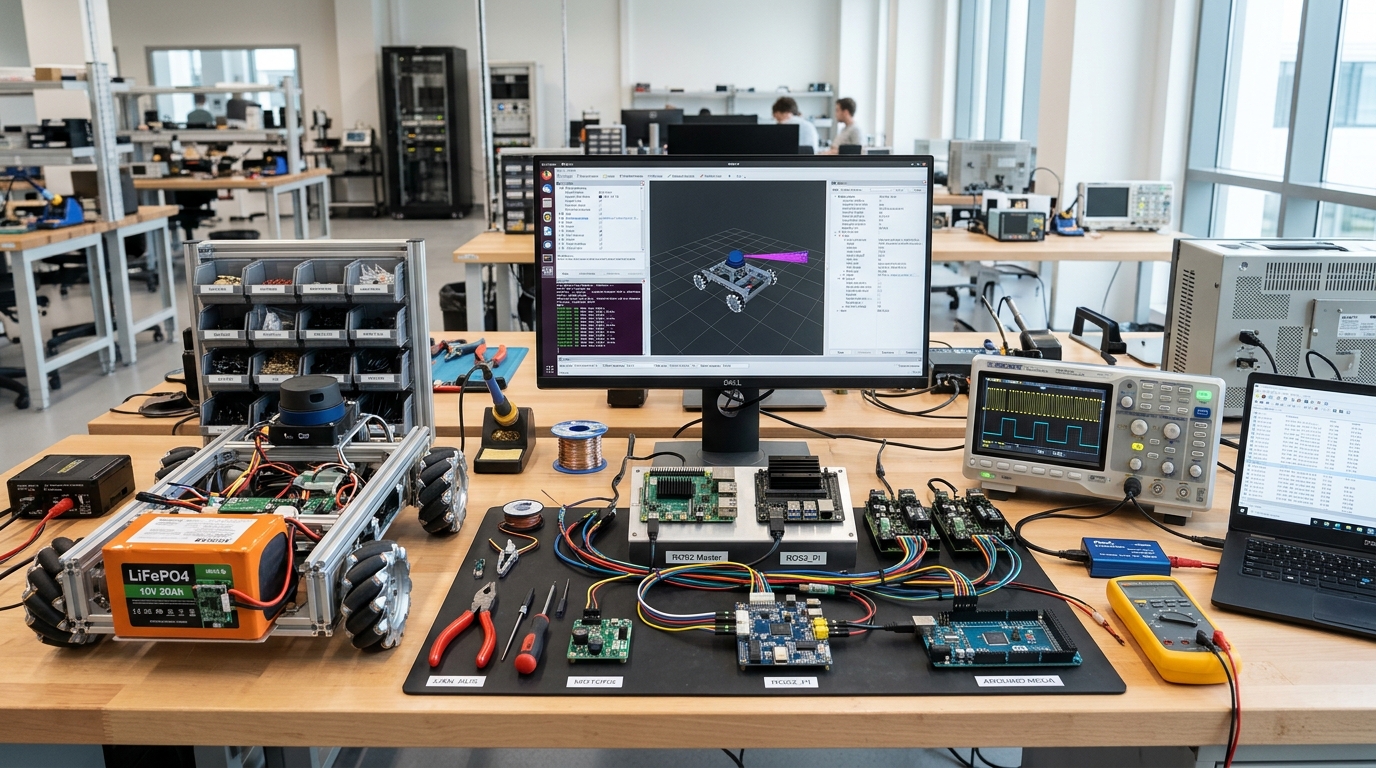
Institute Ignition Grant & Tata InnoVent-27
Institute Ignition Grant of INR 1,00,000 for autonomous robotics prototyping, and Top 100 nationwide selection from 7,500+ submissions in Tata Technologies InnoVent-27.
Education & Roles.
Undergraduate mechanical engineering studies and student leadership responsibilities.
NIT Andhra Pradesh
IIT Madras
Selected for final-year coursework at the Department of Engineering Design through the institute exchange program.
Joint Secretary
Coordinated student innovation activities, hackathon organization, and student prototype support.
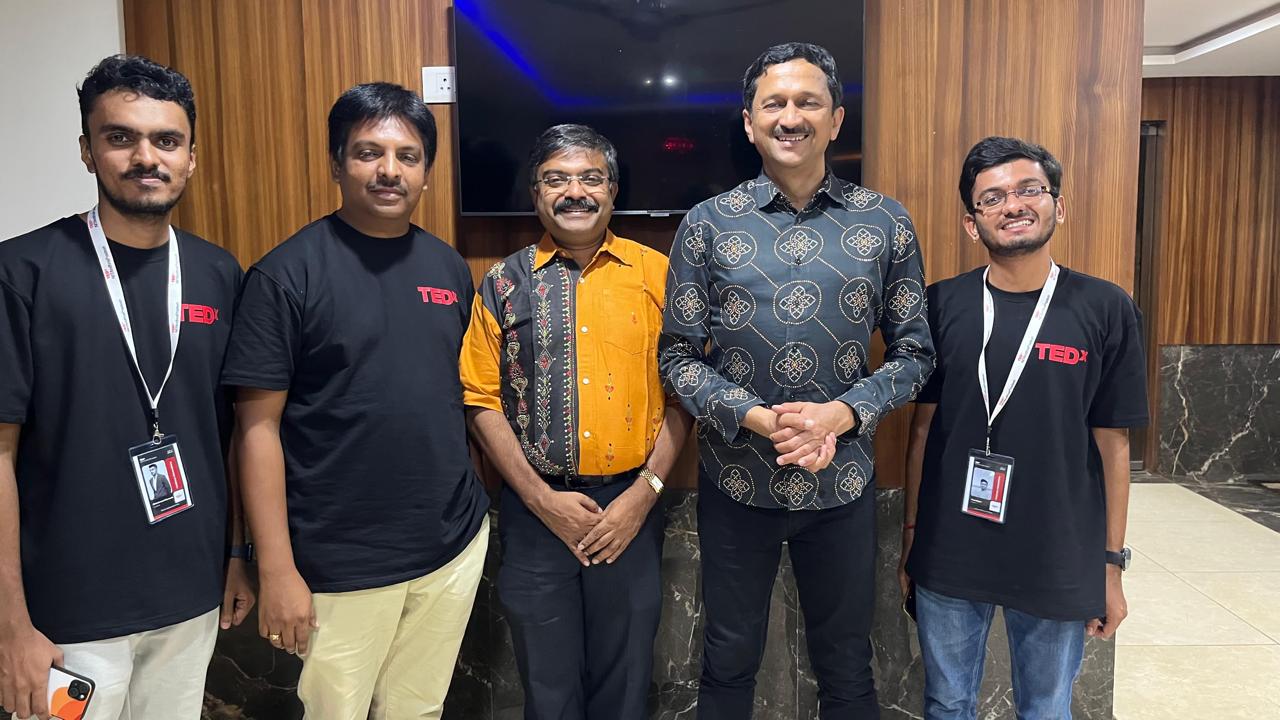
Curation Team
Assisted in curating technical and design speakers for institutional TEDx events.
Event Planning Team
Organized developer sessions and hands-on workshops across technical domains.
Joint Secretary
Managed student media design, digital communication, and design workshops.
Theory of Industrial Robotics and Applications
Manipulator kinematics, dynamics, trajectory planning, and industrial robot actuation.
ROS2 Navigation Stack with SLAM
Nav2 costmaps, path planners, SLAM Toolbox mapping, and simulation pipelines.
Data Analytics Certification
Relational database queries, data analysis pipelines, and reporting.
Technical Arsenal.
Hands-on technical stack validated across autonomous electric vehicles, planetary exploration simulations, and edge AI vision platforms.
Autonomous Navigation & Middleware
ROS2 & Simulation Infrastructure
Kinematic modeling, multi-agent navigation, and simulated sensor transport for terrestrial and extraterrestrial rovers.
Vehicle Dynamics & Closed-Loop Control
Drive-by-Wire & Trajectory Tracking
Real-time steering and throttle controllers, deterministic path tracking, and human-in-the-loop takeover mechanisms.
Perception & Edge Vision
Camera Calibration & Geometric Vision
Sub-pixel target detection, camera intrinsic/extrinsic parameter estimation, and real-time vision pose correction.
Embedded Systems & Core Languages
Real-Time Embedded & Telemetry
Deterministic real-time code execution, Linux system integration, and operator telemetry interfaces.
Mechanical Engineering & CAD
Motorsport Chassis & FEA Analysis
Vehicle spaceframe engineering, powertrain mounting, kinematic linkage analysis, and competition technical documentation.
Data Analytics & Telemetry Modeling
Fleet Analytics & Sensor Logging
Vehicle CAN bus log processing, inventory SKU tracking, and operational metric dashboards.